

CMU Foam Hands Lab DexKit soft hand
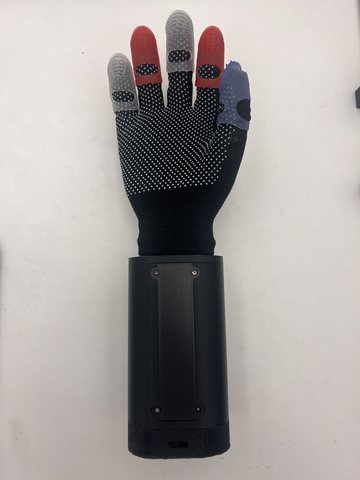
Specifications
Record source date: 2026-10-02
Active / total DOF: 12 / —
Weight basis: Hand-only mass not established in the reviewed source.
Availability / status: 2026 research platform; project page still incomplete
Evidence limits: 12 actuated hand DOF excludes four gantry axes. Project site contains unfinished documentation; do not treat as a validated turnkey build or shipping product.
Price scope: CMU describes a complete platform below USD 2,000 including a four-axis gantry; no separate hand price established.
Software, projects & datasets
What is ready to build with?
A software-support statement is not established in this record.
Product source ↗Check each link’s model scope, release, files and license. A reference is not a tested integration.
Dexhands has not reproduced a software setup or hardware test for this record. Published support is not a test result.
Curated public references, checked 2026-10-02. Links describe a model or family relationship, not hardware-tested compatibility.
DexKit thesis presentation
CMU Foam Hands Lab · Research use
CMU thesis source describing the soft hand and complete manipulation platform.
Whole-kit cost and gantry axes must not be compared as hand-only specifications.
Learn to audit a model-to-hand interface →