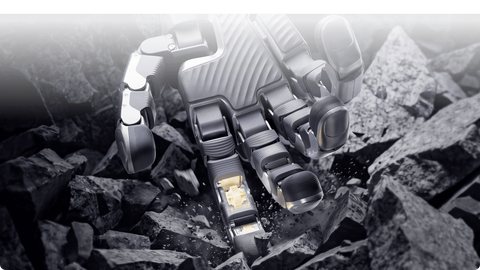
Dex5-S
Unitree Robotics
Explore the standard and Pro configurations, including their different tactile options.
DEXTEROUS MANIPULATION
Compare hardware. Discover applications. Share what works. An open reference and community for dexterous manipulation.
Dexhands Association
Find the right hand, explore the code, and learn how dexterity works.
An open community for researchers, builders and curious minds. About Dexhands
New to our catalog. Explore the designs and the evidence behind them.
Unitree Robotics
Explore the standard and Pro configurations, including their different tactile options.
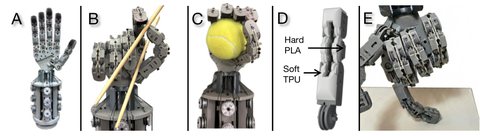
UIUC / UC Irvine
A tendon-driven design with rigid links and compliant joints. Find the authors’ CAD, API and simulation model.
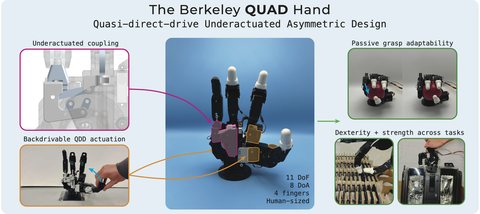
UC Berkeley
Four fingers, eight actuators, eleven degrees of freedom. Read how the design combines independent and coupled motion.
Dates show when these records were added or reviewed here. Manufacturer claims and research results retain their original scope.
Follow Xynova Prima 1 from its public specifications to your first experiment plan.
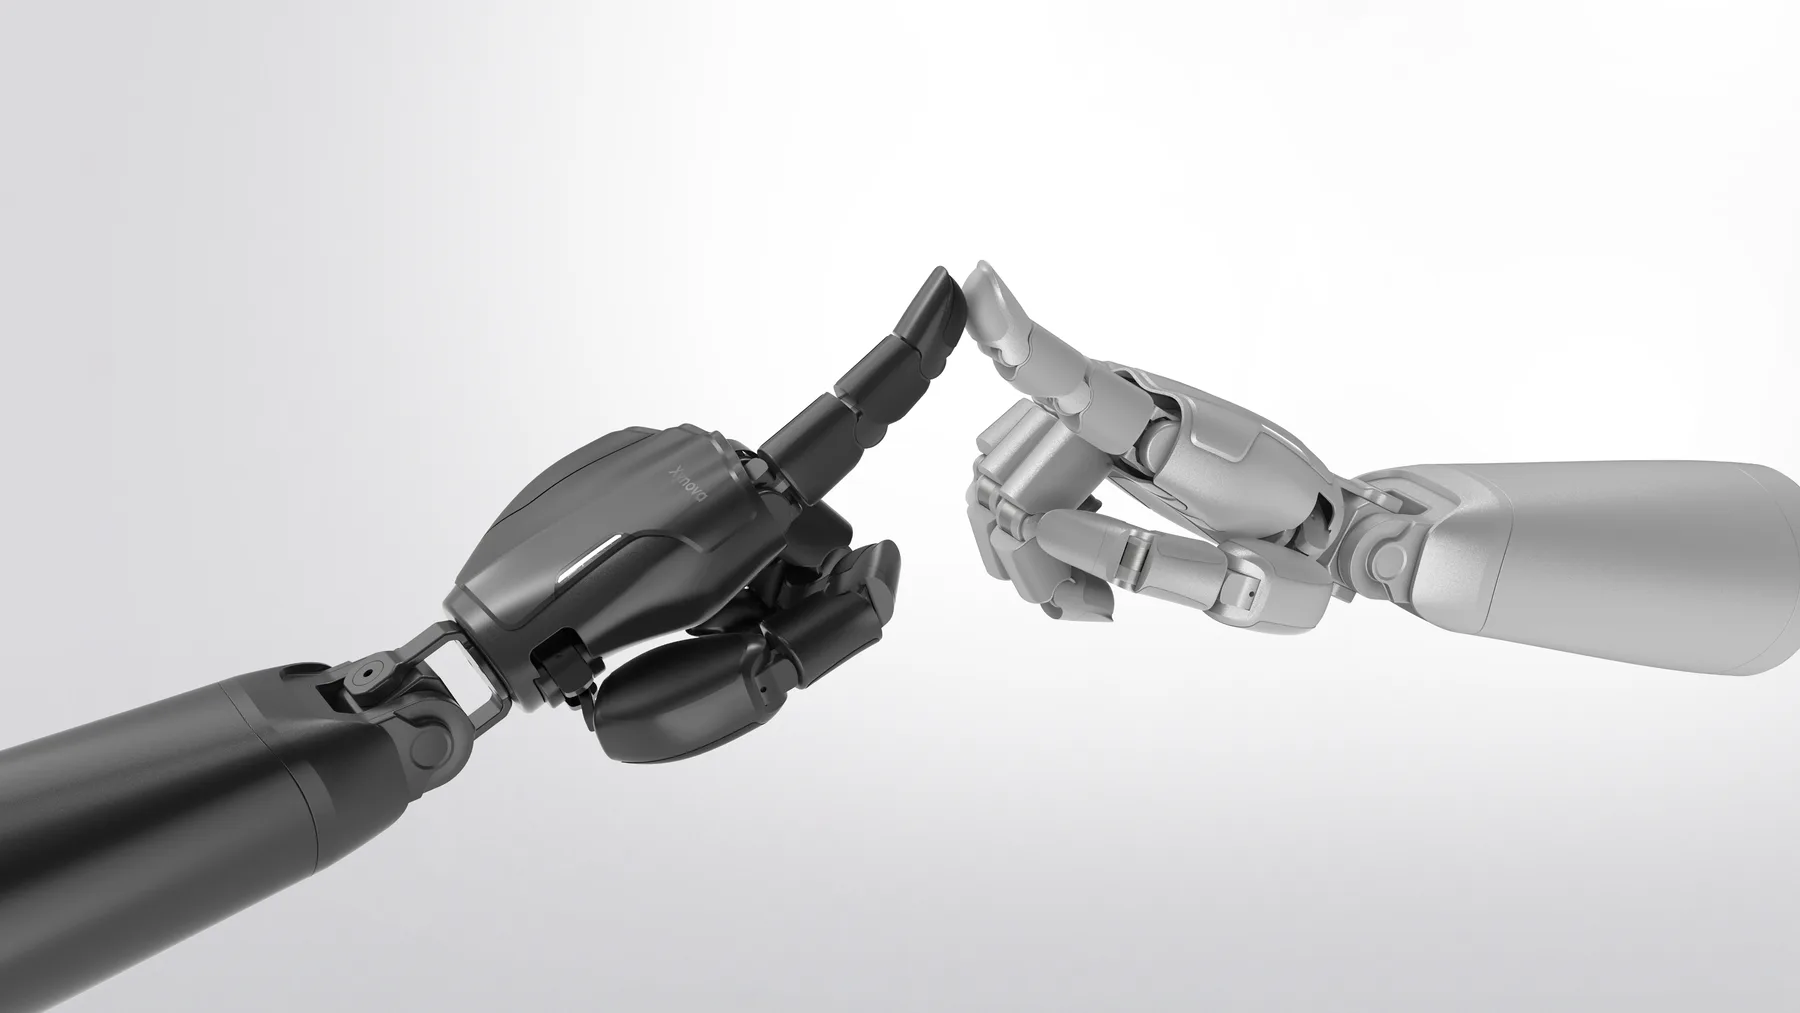
Start with Prima 1. Compare it with Flex 2 to see which motion, sensing and interface details need checking.
Read the public documentation. Confirm the SDK, commanded axes, sensor streams and any model files for your exact unit.
Choose pen reorientation, delicate handling or data collection. Download a brief with the signals and results to record.
Planning example, not a completed hardware test. A runnable Prima 1 SDK or simulator has not been verified for this guide; confirm the released package before execution.
BEYOND THE SCREEN