

LEAP Hand / Carnegie Mellon LEAP Hand v1
Understand this hand
LEAP Hand v1 is an open research platform with an assembly route, development API and linked simulation work. It is a useful starting point for studying a reproducible hand setup.
- What distinguishes it
- The project links CAD, robot models and software. Its published build cost describes a research build, not a universal delivered-system quote.
- Before you build
- Pin the v1 hardware and software revisions. Confirm parts availability, build effort and the simulator used by the experiment you want to reproduce.
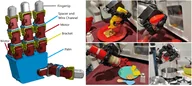
Evidence review · 2026-09-25
Manufacturer, author and seller statements checked against public sources. This is not an independent hardware test. Fields outside this review retain their earlier evidence dates.
- Model / DOF
- V1 retained as its own generation; not V2 Standard or Advanced. Existing 16-axis value retained; not freshly established by the homepage text. Source ↗
- Weight
- No new weight measurement or confirmed assembly boundary in this review; retain previous dated evidence. Source ↗
- Price
- USD 1,771.74 regular parts total, dated August 2023. Historical BOM, not a current finished-hand price; tools, labor and delivery additional. Source ↗
- Software / availability
- Author API exists; build platform, not a confirmed ready-to-ship commercial offer. Source ↗
Specifications
Record source date: 2026-09-02
Active / total DOF: 16 / 16
Servo position, velocity, current, voltage and temperature; no tactile skin standard
Weight basis: 595 g
Availability / status: Open hardware / buildable
Evidence limits: DIY/open-hardware project. Build-cost estimate excludes purchased assembly/service and is not a comparable commercial sale price.
Price scope: USD 1,771.74 regular parts total, dated August 2023. Historical BOM, not a current finished-hand price; tools, labor and delivery additional.
Start with LEAP Hand v1
Inspect one simulated cube-reorientation rollout before connecting hardware.
The authors publish a v1 API and an Isaac Lab environment. Dexhands reviewed the instructions; we have not run this simulation or tested the hand.
Sources reviewed 2026-09-30 · no hardware connection from this pageBefore you start: versions and requirements
LEAP Hand v1. The environment README reports Ubuntu 22.04, Isaac Sim 4.5 and Isaac Lab 2.1.0. Record the repository commit you actually use.
- A workstation meeting the linked Isaac Sim requirements.
- The environment, its documented dependencies and the checkpoint expected by its playback instructions.
- A place to save the console log, configuration and a short rollout recording.
Match the environment
Follow the environment installation instructions. Keep the v1 model separate from LEAP v2 Standard and Advanced. Record the simulator versions and commit before changing parameters.
Environment installationTry the published simulation playback
After the upstream setup and checkpoint requirements are satisfied, use its single-environment playback example. This is simulation; do not run the deployment scripts for this first check.
Playback instructionspython scripts/rl_games/play.py --task Isaac-Reorient-Cube-Leap --num_envs 1Check what actually happened
Record whether the model loads, the policy steps and the cube moves as expected. Keep failed runs and errors. A moving simulation is a setup check, not evidence of real-world grasp reliability.
Plan a reproducible evaluation
What counts as a useful result?
- The selected environment starts without missing-asset or dependency errors.
- The log identifies the model, software versions, commit and checkpoint.
- The report separates observed behavior from expected behavior, including failures.
If something does not work
- Import or asset failure
- Compare your installed versions and downloaded assets with the environment README before changing the task.
- Wrong hand generation
- v1 and the two v2 variants have different designs. A shared brand name does not establish controller compatibility.
- Simulation versus hardware
- The hardware API has its own port, joint-convention and commissioning requirements. Motor current is not a calibrated fingertip-force measurement.
Prepare an experiment report
Fill in observed results and failures. Keep credentials, serial numbers and confidential designs out of public reports.
Enable JavaScript to continue to the discussion editor, or copy this template manually.
Guide updates
· Added a simulation-first route, upstream environment versions, acceptance checks and an experiment-report template.
Software, projects & datasets
What is ready to build with?
Author-linked API repository; select this generation. No hardware compatibility test performed.
Product source ↗Check each link’s model scope, release, files and license. A reference is not a tested integration.
Dexhands has not reproduced a software setup or hardware test for this record. Published support is not a test result.
Curated public references, checked 2026-09-22. Links describe a model or family relationship, not hardware-tested compatibility.
Dexterous hand URDF collection
DexSuite · Family resource
Research-maintained visual and collision models for multiple hand families.
Inspect the model directory and upstream asset license; revision, size and sensor geometry may differ from your hand.
Hand motion retargeting
DexSuite · Family resource
Human-to-robot motion optimizers with configurations for the listed hand families.
Retargeting generates joint targets; it is not a device driver. Verify model geometry and joint order.
LEAP Hand v1 API
LEAP Hand · Model-specific
Python, C++, ROS and ROS 2 interfaces for the original LEAP Hand.
For v1 hardware. LEAP v2 Standard and Advanced use separate repositories.
LEAP Hand in Isaac Lab
LEAP Hand · Model-specific
Simulation and learning environment for LEAP Hand v1.
Check the required Isaac Lab release and v1 hardware configuration.
LEAP Hand in Isaac Gym
LEAP Hand · Model-specific
Original v1 simulation code accompanying the LEAP Hand project.
Uses the older Isaac Gym stack; it is distinct from the Isaac Lab implementation.
Bimanual glove teleoperation
LEAP Hand / Bimanual Dexterity · Research use
Glove-based control examples for LEAP Hand experiments.
Gloves, calibration and the specified robot setup are required.
DexCap capture and learning pipeline
DexCap authors · Research use
Motion capture processing, LEAP retargeting and demonstration dataset tools.
The project uses its own capture rig and robot setup; raw human motion needs retargeting.
Learn to audit a model-to-hand interface →