

LEAP Hand / Carnegie Mellon LEAP Hand v2 Standard
Understand this hand
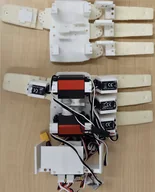
LEAP Hand v2 Standard uses a hybrid rigid–soft design and underactuated finger curling. Its project page distinguishes eight powered motors from 16 total DOF.
- What distinguishes it
- Coupled finger motion changes what can be controlled independently. This is a separate design from v1 and v2 Advanced.
- Before you build
- Inspect the current assembly and release links for this exact variant. Do not assume a v1 controller or a v2 Advanced model fits it.
Evidence review · 2026-09-25
Manufacturer, author and seller statements checked against public sources. This is not an independent hardware test. Fields outside this review retain their earlier evidence dates.
- Model / DOF
- 8 motors / 16 total DOF; coupled finger motion. Source ↗
- Weight
- No new weight measurement or confirmed assembly boundary in this review; retain previous dated evidence. Source ↗
- Price
- About USD 300 parts estimate on current parts page; homepage still says USD 200. Not a finished-hand quotation. Source ↗
- Software / availability
- Demo page describes software tools; runnable release and delivery not validated in this review. Source ↗
Specifications
Record source date: 2026-09-02
Active / total DOF: 8 / 16
Smart-servo proprioception; no base tactile skin
Weight basis: Not published
Availability / status: Open hardware / buildable
Evidence limits: DIY/open-hardware project. Build-cost estimate excludes purchased assembly/service and is not a comparable commercial sale price.
Price scope: About USD 300 parts estimate on current parts page; homepage still says USD 200. Not a finished-hand quotation.
Software, projects & datasets
What is ready to build with?
A software-support statement is not established in this record.
Product source ↗Check each link’s model scope, release, files and license. A reference is not a tested integration.
Dexhands has not reproduced a software setup or hardware test for this record. Published support is not a test result.
Curated public references, checked 2026-09-22. Links describe a model or family relationship, not hardware-tested compatibility.
LEAP Hand v2 Standard API
LEAP Hand · Model-specific
Python and ROS 2 control, serial setup and calibration for LEAP v2.
For the standard v2 configuration; do not use the Advanced motor mapping.
Learn to audit a model-to-hand interface →