

UIUC / UC Irvine CRAFT Hand
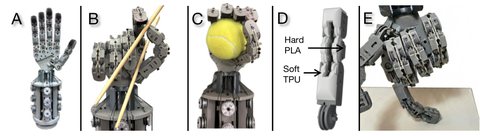
Specifications
Record source date: 2026-10-02
Active / total DOF: 15 / 20
Weight basis: Paper reports 800 g; hand / forearm boundary is not separately itemized.
Availability / status: Research prototype
Evidence limits: 15 active and five passive DOF. Pull-out retention and teleoperated demonstrations are not generic fingertip-force or autonomous-performance ratings.
Price scope: Authors describe a build under USD 600. A motor bundle is not a complete hand.
Software, projects & datasets
What is ready to build with?
Author CAD, API, MJCF and camera-teleoperation repositories
Product source ↗Check each link’s model scope, release, files and license. A reference is not a tested integration.
Dexhands has not reproduced a software setup or hardware test for this record. Published support is not a test result.
Curated public references, checked 2026-10-02. Links describe a model or family relationship, not hardware-tested compatibility.
CRAFT print files
UIUC / UC Irvine · Model-specific
Author-linked resources for the CRAFT research hand.
Verify repository license, actuator configuration and current build instructions.
CRAFT control API
UIUC / UC Irvine · Model-specific
Author-linked resources for the CRAFT research hand.
Verify repository license, actuator configuration and current build instructions.
CRAFT MJCF
UIUC / UC Irvine · Model-specific
Author-linked resources for the CRAFT research hand.
Verify repository license, actuator configuration and current build instructions.
Learn to audit a model-to-hand interface →