

F-TAC Hand research team F-TAC Hand
Specifications
Record source date: 2026-09-23
Active / total DOF: 6 / —
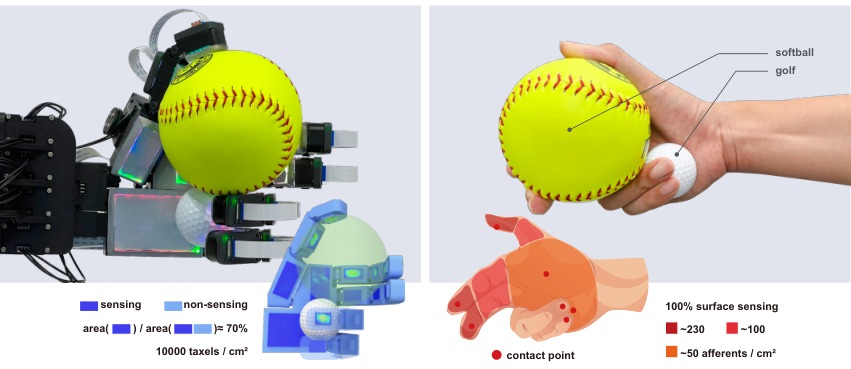
17 vision-based tactile sensors; authors report 70% palmar coverage and 0.1 mm spatial resolution
Weight basis: Hand-only mass not established in the reviewed source.
Availability / status: Research design; commercial availability unverified
Evidence limits: Six actuation channels counted from the described five finger drives plus thumb opposition. Tactile performance and grasp results belong to the authors’ experimental setup; complete joint count and hand-only mass not verified here.
Software, projects & datasets
What is ready to build with?
A software-support statement is not established in this record.
Product source ↗Check each link’s model scope, release, files and license. A reference is not a tested integration.
Dexhands has not reproduced a software setup or hardware test for this record. Published support is not a test result.
Curated public references, checked 2026-09-23. Links describe a model or family relationship, not hardware-tested compatibility.
F-TAC Hand — original research
F-TAC Hand research team · Research use
Original research reference describing this hand or platform and its tested configuration.
Six actuation channels counted from the described five finger drives plus thumb opposition. Tactile performance and grasp results belong to the authors’ experimental setup; complete joint count and hand-only mass not verified here.
Learn to audit a model-to-hand interface →