

SCHUNK SVH five-finger hand, left / right
Understand this hand
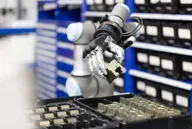
SCHUNK SVH is a five-finger servo-electric gripping hand. The manufacturer presents it as a platform for human-like gripping and research integration.
- What distinguishes it
- Its multiple joints and drive layout should be interpreted through the exact model documentation, rather than treating finger count as an independent-control count.
- Before you build
- Confirm the left or right model, wrist interface, controller package and available software. Evaluate the complete mounted assembly against your arm’s requirements.
Specifications
Record source date: 2026-09-16
Active / total DOF: 9 / 20
Motor/joint feedback; maker does not list fingertip tactile sensing as standard
Weight basis: Hand including wrist electronics; FWK tool interface separately required
Availability / status: Current / marketed
Evidence limits: Current numeric price not verified. Historical 2019 EUR45,000 incl.VAT reference is intentionally excluded from current price.
Software, projects & datasets
What is ready to build with?
Check each link’s model scope, release, files and license. A reference is not a tested integration.
Dexhands has not reproduced a software setup or hardware test for this record. Published support is not a test result.
Curated public references, checked 2026-09-22. Links describe a model or family relationship, not hardware-tested compatibility.
Dexterous hand URDF collection
DexSuite · Family resource
Research-maintained visual and collision models for multiple hand families.
Inspect the model directory and upstream asset license; revision, size and sensor geometry may differ from your hand.
Hand motion retargeting
DexSuite · Family resource
Human-to-robot motion optimizers with configurations for the listed hand families.
Retargeting generates joint targets; it is not a device driver. Verify model geometry and joint order.
SVH ROS 2 driver
SCHUNK · Model-specific
Manufacturer ROS 2 driver, descriptions and simulation integration for SVH.
Use the supported ROS distribution and the correct hand side.
SVH C++ library
SCHUNK · Model-specific
Low-level C++ communication library for the SCHUNK SVH.
Check hardware initialization and limit settings in the manufacturer documentation.
Learn to audit a model-to-hand interface →