

Robotiq 3-Finger Adaptive Robot Gripper
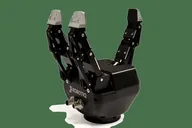
Specifications
Record source date: 2026-09-16
Active / total DOF: 4 / 11
Finger position, object detection and motor current; selectable force/speed/position
Weight basis: 2.3 kg
Availability / status: Current / marketed
Evidence limits: Adaptive three-finger gripper; 11 joints are not 11 independent DoF. Manufacturer reference sheet is dated2020.
Price scope: EUR19,960 seller listing excluding VAT; accessory/integration scope may alter price
Software, projects & datasets
What is ready to build with?
A software-support statement is not established in this record.
Product source ↗Check each link’s model scope, release, files and license. A reference is not a tested integration.
Dexhands has not reproduced a software setup or hardware test for this record. Published support is not a test result.
Curated public references, checked 2026-09-22. Links describe a model or family relationship, not hardware-tested compatibility.
Robotiq ROS packages
ROS-Industrial · Family resource
Community ROS packages for several Robotiq gripper families.
Legacy ROS stack. Choose the 3-finger or 2-finger package; Hand-E support is not assumed.
Learn to audit a model-to-hand interface →