

Robotiq 2F-140
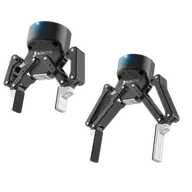
Specifications
Record source date: 2026-09-19
Active / total DOF: — / —
Weight basis: One gripper, product sheet; mounted system may add coupling and sensing.
Availability / status: Adjacent grippers
Evidence limits: Published mass is gripper mass; adapter / sensor packages differ. 140 mm nominal stroke. Adaptive pick-and-place substitute, not an anthropomorphic hand.
Software, projects & datasets
What is ready to build with?
Robot integration packages; exact robot/URCap version must be matched.
Product source ↗Check each link’s model scope, release, files and license. A reference is not a tested integration.
Dexhands has not reproduced a software setup or hardware test for this record. Published support is not a test result.
Curated public references, checked 2026-09-22. Links describe a model or family relationship, not hardware-tested compatibility.
Human-to-robot hand embodiment
DFKI Robotics Innovation Center · Research use
Research code for transferring human motions to several supported robot hands.
Use the project’s specific model, calibration and motion-capture assumptions; mesh licenses vary.
Robotiq ROS packages
ROS-Industrial · Family resource
Community ROS packages for several Robotiq gripper families.
Legacy ROS stack. Choose the 3-finger or 2-finger package; Hand-E support is not assumed.
Learn to audit a model-to-hand interface →