

Prensilia Mia Hand R&D, L/R
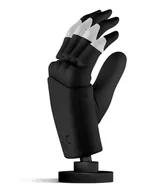
Specifications
Record source date: 2026-09-16
Active / total DOF: 3 / 4
3 position, 3 motor-current and 6 limit sensors; optional 3 force sensors (~50 mN resolution)
Weight basis: ~520 g
Availability / status: Current / marketed
Evidence limits: Force sensors optional; site says force controller available soon. Three actuators/four DoF; coupled fingers.
Software, projects & datasets
What is ready to build with?
Check each link’s model scope, release, files and license. A reference is not a tested integration.
Dexhands has not reproduced a software setup or hardware test for this record. Published support is not a test result.
Curated public references, checked 2026-09-22. Links describe a model or family relationship, not hardware-tested compatibility.
Mia ROS package releases
Prensilia · Family resource
Manufacturer release repository for Mia control and description packages.
Legacy ROS releases; confirm the supported Mia generation. This is not a Mk2 SDK claim.
Human-to-robot hand embodiment
DFKI Robotics Innovation Center · Research use
Research code for transferring human motions to several supported robot hands.
Use the project’s specific model, calibration and motion-capture assumptions; mesh licenses vary.
Learn to audit a model-to-hand interface →