

Agile Robots Agile Hand
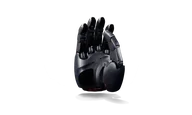
Specifications
Record source date: 2026-09-16
Active / total DOF: — / 21
Position and joint-torque sensing at every actuated joint; optional tactile sensors
Weight basis: Manufacturer hand weight; seller 0.8 kg field conflicts
Availability / status: Current / marketed
Evidence limits: Reported active DOF: 15 or 16. Manufacturer offers15 or16DoF depending configuration; quote must identify which.
Price scope: Seller USD 42,000; backorder. Side, 15/16-axis version and sensor configuration unspecified; shipping and tax extra. Not a manufacturer quote.
Software, projects & datasets
What is ready to build with?
No model-specific public SDK or simulator release has been verified here. Ask for the exact package and installation example.
Dexhands has not reproduced a software setup or hardware test for this record. Published support is not a test result.
Curated public references, checked 2026-09-22. Links describe a model or family relationship, not hardware-tested compatibility.
Model-specific public software or research links have not been verified yet. See the product sources or suggest a resource with its exact hardware revision.
Learn to audit a model-to-hand interface →