

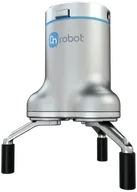
OnRobot 3FG15 three-finger gripper
Specifications
Record source date: 2026-09-16
Active / total DOF: 1 / —
Finger position / object-detection feedback through controller; no tactile skin stated
Weight basis: 1.15 kg
Availability / status: Current / marketed
Evidence limits: Three-finger centric industrial gripper, not independent dexterous fingers. Prior datasheetURL redirects; detailed fields inherited.
Price scope: EUR4,769 seller listing excludingVAT; robot-brand/accessory selection may change price
Software, projects & datasets
What is ready to build with?
A software-support statement is not established in this record.
Product source ↗Check each link’s model scope, release, files and license. A reference is not a tested integration.
Dexhands has not reproduced a software setup or hardware test for this record. Published support is not a test result.
Curated public references, checked 2026-09-22. Links describe a model or family relationship, not hardware-tested compatibility.
3FG15 Python interface
RBEGamer · Model-specific
Community-maintained Python integration for the OnRobot 3FG15.
Third-party software; verify the controller and Modbus configuration.
Learn to audit a model-to-hand interface →