

ROBOTIS RH-P12-RN-UR
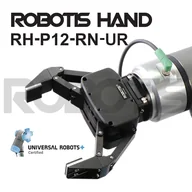
Specifications
Record source date: 2026-09-19
Active / total DOF: 1 / —
Weight basis: 500 g gripper body; complete adapter/package mass not established.
Availability / status: Adjacent grippers
Evidence limits: 500 g is the gripper hardware, not the 2 lb shop metadata or complete package. 106 mm stroke; 170 N maximum grip is not fingertip force. Availability needs confirmation.
Price scope: US maker listing; one assembled gripper plus listed accessories. Includes UR frame, cable and URCap media. Shipping calculated separately; confirm tax and availability.
Software, projects & datasets
What is ready to build with?
DYNAMIXEL protocol 2.0 / RS-485; UR e-Series package with URCap
Product source ↗Check each link’s model scope, release, files and license. A reference is not a tested integration.
Dexhands has not reproduced a software setup or hardware test for this record. Published support is not a test result.
Curated public references, checked 2026-09-22. Links describe a model or family relationship, not hardware-tested compatibility.
RH-P12-RN ROS packages
ROBOTIS · Family resource
Original control, description and Gazebo packages for RH-P12-RN.
Archived by the manufacturer in 2025. RN(A) and UR integration use different packages.
Learn to audit a model-to-hand interface →