

AgiBot OmniHand 2025 Tactile
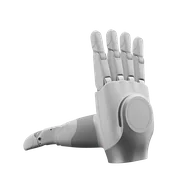
Specifications
Record source date: 2026-09-16
Active / total DOF: 10 / 16
>400 tactile taxels, 0–20 N range and 0.1 N stated resolution, plus proprioceptive telemetry
Weight basis: ≤550 g
Availability / status: Current / marketed
Evidence limits: Official store table labels sensor resolution0.1A (unit error); prior manual says0.1N while collectionFAQ says0.2N. No resolution harmonization made. Product load table1kg typical versusFAQ500g rated; confirm revision.
Price scope: USD5,360 default single left-hand selection; right-hand option listed. Taxes, duties and shipping extra.
Software, projects & datasets
What is ready to build with?
Windows; SDK and Python examples; ROS2 support in development per undated storeFAQ
Product source ↗Check each link’s model scope, release, files and license. A reference is not a tested integration.
Dexhands has not reproduced a software setup or hardware test for this record. Published support is not a test result.
Curated public references, checked 2026-09-22. Links describe a model or family relationship, not hardware-tested compatibility.
OmniHand SDK
AgiBot · Family resource
Manufacturer C++, Python and ROS 2 integration for listed OmniHand models.
O10, O12, H3L and H3U_M support differs by interface; verify tactile and Ultra-M support in the API table.
Learn to audit a model-to-hand interface →