

OYMotion ROH-A002
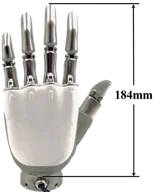
Specifications
Record source date: 2026-09-02
Active / total DOF: 6 / 11
Magnetic/position encoders and motor-current-derived force; no tactile skin
Weight basis: A002 545 g
Availability / status: Current / marketed
Evidence limits: Only common 6-active/11-joint architecture and SDK/model documentation freshly checked unless extra verified fields listed. Legacy detailed specifications remain historical.
Price scope: Robotopian selected ROH-A002 / RS485 / Left / Black: USD 9,750
Software, projects & datasets
What is ready to build with?
Check each link’s model scope, release, files and license. A reference is not a tested integration.
Dexhands has not reproduced a software setup or hardware test for this record. Published support is not a test result.
Curated public references, checked 2026-09-22. Links describe a model or family relationship, not hardware-tested compatibility.
ROHand ROS 2 integration
OYMotion · Family resource
Manufacturer ROS 2 packages linked from the ROHand firmware project.
Confirm the exact model, bus and firmware; sensor interfaces are not identical across variants.
ROHand ROS 2 descriptions
OYMotion · Family resource
Manufacturer description packages for visualizing and integrating ROHand.
Check the available model folders; a description does not establish working hardware control.
ROHand firmware and protocol
OYMotion · Family resource
Manufacturer firmware and communication documentation with links to ROS packages.
Match the model, protocol and firmware. AP, Lite and ROHand variants differ.
Learn to audit a model-to-hand interface →