

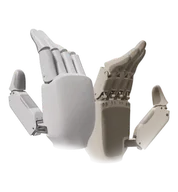
Fourier Intelligence FDH-6
Specifications
Record source date: 2026-09-02
Active / total DOF: 6 / 11
Position and speed feedback; no tactile skin stated
Weight basis: 515 g
Availability / status: Current / marketed
Evidence limits: Current official SDK/integration docs verify FDH-6 support. Mechanical specifications remain prior snapshot; dynamic product page was not readable.
Software, projects & datasets
What is ready to build with?
Check each link’s model scope, release, files and license. A reference is not a tested integration.
Dexhands has not reproduced a software setup or hardware test for this record. Published support is not a test result.
Curated public references, checked 2026-09-22. Links describe a model or family relationship, not hardware-tested compatibility.
Fourier hand teleoperation
Fourier · Family resource
Manufacturer humanoid teleoperation and data collection with 6-DOF and 12-DOF hand configurations.
Uses the Fourier robot stack. The README lists 12-DOF tactile support as unfinished.
Fourier DexHand SDK
Fourier · Family resource
Linux Python and C++ interfaces using UDP communication.
Confirm the device and firmware with Fourier; FDH-12 compatibility is not established by this link.
Learn to audit a model-to-hand interface →