

DH-Robotics DH-5-6 humanoid dexterous hand
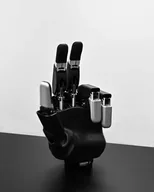
Specifications
Record source date: 2026-09-02
Active / total DOF: 6 / 11
Position/current feedback; optional multipoint tactile
Weight basis: 790 g
Availability / status: Current / marketed
Evidence limits: Manufacturer specifications take precedence over conflicting seller tables. Original payload figures retain prior provenance; tip force 25 N and 790 g mass freshly verified.
Price scope: Robotics Center selected DH-5-6: USD 5,500 per hand
Software, projects & datasets
What is ready to build with?
A software-support statement is not established in this record.
Product source ↗No model-specific public SDK or simulator release has been verified here. Ask for the exact package and installation example.
Dexhands has not reproduced a software setup or hardware test for this record. Published support is not a test result.
Curated public references, checked 2026-09-22. Links describe a model or family relationship, not hardware-tested compatibility.
Model-specific public software or research links have not been verified yet. See the product sources or suggest a resource with its exact hardware revision.
Learn to audit a model-to-hand interface →