

NYU / NYU Shanghai RUKA-v2
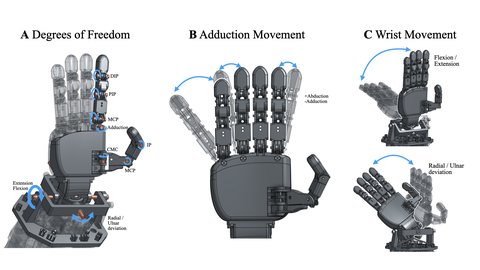
Specifications
Record source date: 2026-10-02
Active / total DOF: — / —
Optional magnetic encoders and tactile attachments
Weight basis: Hand-only mass not established in the reviewed source.
Availability / status: Research prototype
Evidence limits: DOF unresolved: project caption says 16 across fingers/thumb, paper v2 caption says 18 plus two wrist axes. No normalized hand-only active or total count assigned. Do not mix with original RUKA.
Price scope: Project describes under USD 2,000; paper v2 says under USD 1,500 in its accessibility section. Assembly includes wrist / forearm. Reconcile BOM revision before budgeting.
Software, projects & datasets
What is ready to build with?
Public build instructions, controller and calibration code
Product source ↗Check each link’s model scope, release, files and license. A reference is not a tested integration.
Dexhands has not reproduced a software setup or hardware test for this record. Published support is not a test result.
Curated public references, checked 2026-10-02. Links describe a model or family relationship, not hardware-tested compatibility.
RUKA-v2 repository
NYU / NYU Shanghai · Model-specific
Author repository for the second-generation hand and wrist.
Reconcile hardware revision and DOF discrepancy before integration.
RUKA-v2 assembly guide
NYU / NYU Shanghai · Model-specific
Documented research build workflow.
Budget the complete wrist / forearm assembly and optional sensors separately.
Learn to audit a model-to-hand interface →