

qbrobotics qb SoftHand Research
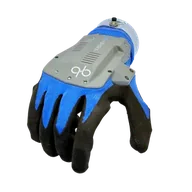
Specifications
Record source date: 2026-09-16
Active / total DOF: 1 / 19
Motor position and current; contact inferred without standard tactile array; optional integration possible
Weight basis: 0.77 kg
Availability / status: Current / marketed
Evidence limits: 19 mechanical DoF are controlled by only 1 or 2 motor synergies; not 19 independent axes.
Price scope: EUR9,000 seller listing; VAT/shipping treatment not verified
Software, projects & datasets
What is ready to build with?
Check each link’s model scope, release, files and license. A reference is not a tested integration.
Dexhands has not reproduced a software setup or hardware test for this record. Published support is not a test result.
Curated public references, checked 2026-09-22. Links describe a model or family relationship, not hardware-tested compatibility.
SoftHand Research downloads
qbrobotics · Model-specific
Manufacturer documentation and software download entry point.
Select the Research model and the relevant robot integration.
Learn to audit a model-to-hand interface →