

Festo BionicSoftHand 2.0
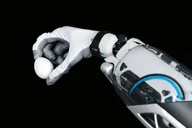
Specifications
Record source date: 2026-09-19
Active / total DOF: — / 11
113 tactile force sensors; 10 bending sensors; 14 pressure sensors
Weight basis: One BionicSoftHand 2.0 including wrist per concept datasheet.
Availability / status: Research platform
Evidence limits: 2020 concept. The 11-DOF count includes the wrist; active hand-only DOF is not isolated. Up to 4 kg load depends on orientation. Not a commercial delivery promise.
Software, projects & datasets
What is ready to build with?
Research demonstration; supported commercial SDK not verified.
Product source ↗No model-specific public SDK or simulator release has been verified here. Ask for the exact package and installation example.
Dexhands has not reproduced a software setup or hardware test for this record. Published support is not a test result.
Curated public references, checked 2026-09-22. Links describe a model or family relationship, not hardware-tested compatibility.
Model-specific public software or research links have not been verified yet. See the product sources or suggest a resource with its exact hardware revision.
Learn to audit a model-to-hand interface →