

Seed Robotics RH8D Adult Dexterous Robot Hand, L/R
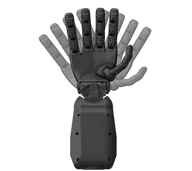
Specifications
Record source date: 2026-09-16
Active / total DOF: 8 / 19
Position, speed, current, temperature, overload/PWM on actuated axes; palm ToF; optional capacitive pads and FTS-1/FTS-3 tactile (1 mN resolution, up to 30 N)
Weight basis: One RH8D hand including actuators and spherical wrist: 0.620 kg.
Availability / status: Current / marketed
Evidence limits: Published DoF counts include wrist and mechanically coupled finger motion; actuator count is the independent command count.
Price scope: From EUR5,599 per hand; tax/fees and optional sensors/mounts extra
Software, projects & datasets
What is ready to build with?
Check each link’s model scope, release, files and license. A reference is not a tested integration.
Dexhands has not reproduced a software setup or hardware test for this record. Published support is not a test result.
Curated public references, checked 2026-09-22. Links describe a model or family relationship, not hardware-tested compatibility.
Seed hand ROS packages
Seed Robotics · Family resource
Control and sensor packages covering RH8D, RH6D, RH4D and RH2D families.
Select the matching motor configuration; this repository uses ROS 1.
RH8D ROS 2 packages
Seed Robotics · Model-specific
Manufacturer ROS 2 control packages for RH8D.
The publisher labels the ROS 2 implementation as still in development.
RH8D hand demo tool
Seed Robotics · Model-specific
A standalone Python interface for testing an RH8D hand.
Follow the hardware connection and calibration instructions.
Learn to audit a model-to-hand interface →